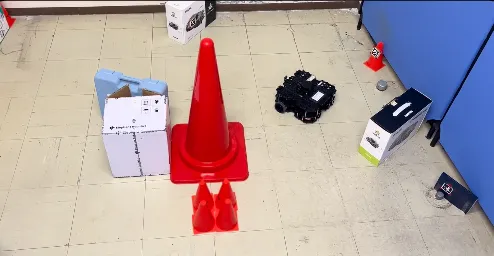
TurtleBot Autonomous Navigation
Autonomous navigation and mapping for a TurtleBot in cluttered indoor environments, combining global path planning with visual servoing and an AprilTag landmark infrastructure to defeat odometry drift.
Robotics · Automation · Applied ML
Automotive and Robotics Engineering student at BINUS ASO, building robots that navigate, see, and decide. Based in West Jakarta, Indonesia.
Autonomous navigation and mapping for a TurtleBot in cluttered indoor environments, combining global path planning with visual servoing and an AprilTag landmark infrastructure to defeat odometry drift.
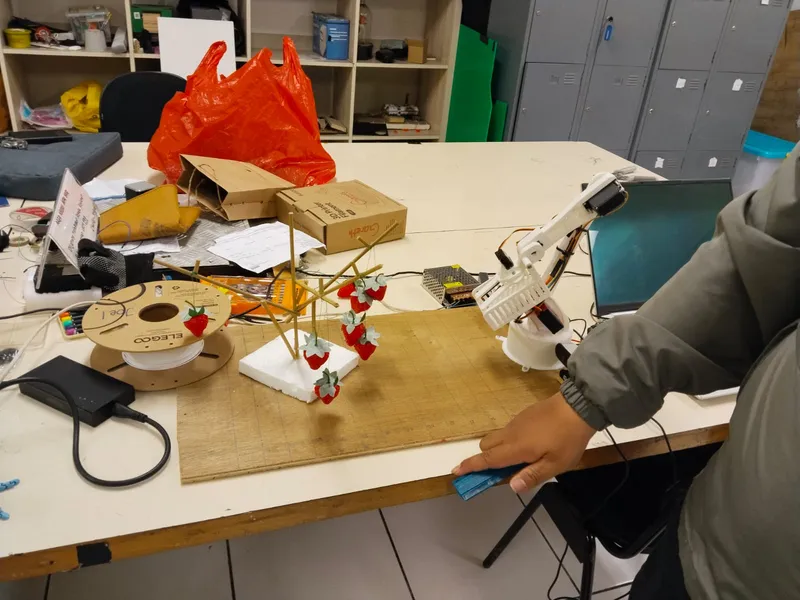
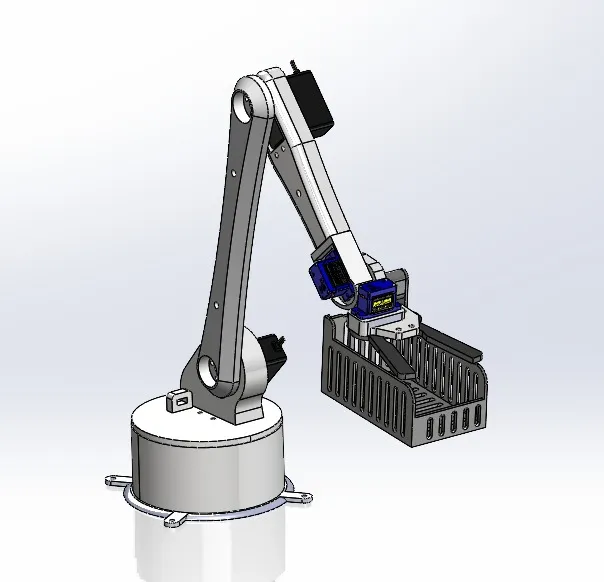
Autonomous robotic arm for precision strawberry harvesting, taken from cardboard mockup to a fully 3D-printed working prototype with vision-driven actuation.
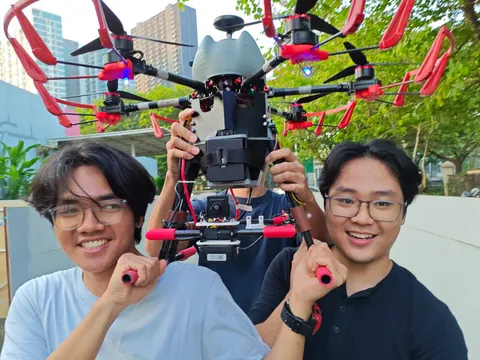
Autonomous drone carrying three LiDAR sensors for obstacle avoidance and mapping, plus a dual-camera setup: front-facing for gate detection and navigation, bottom-facing for object detection and mission tasks.
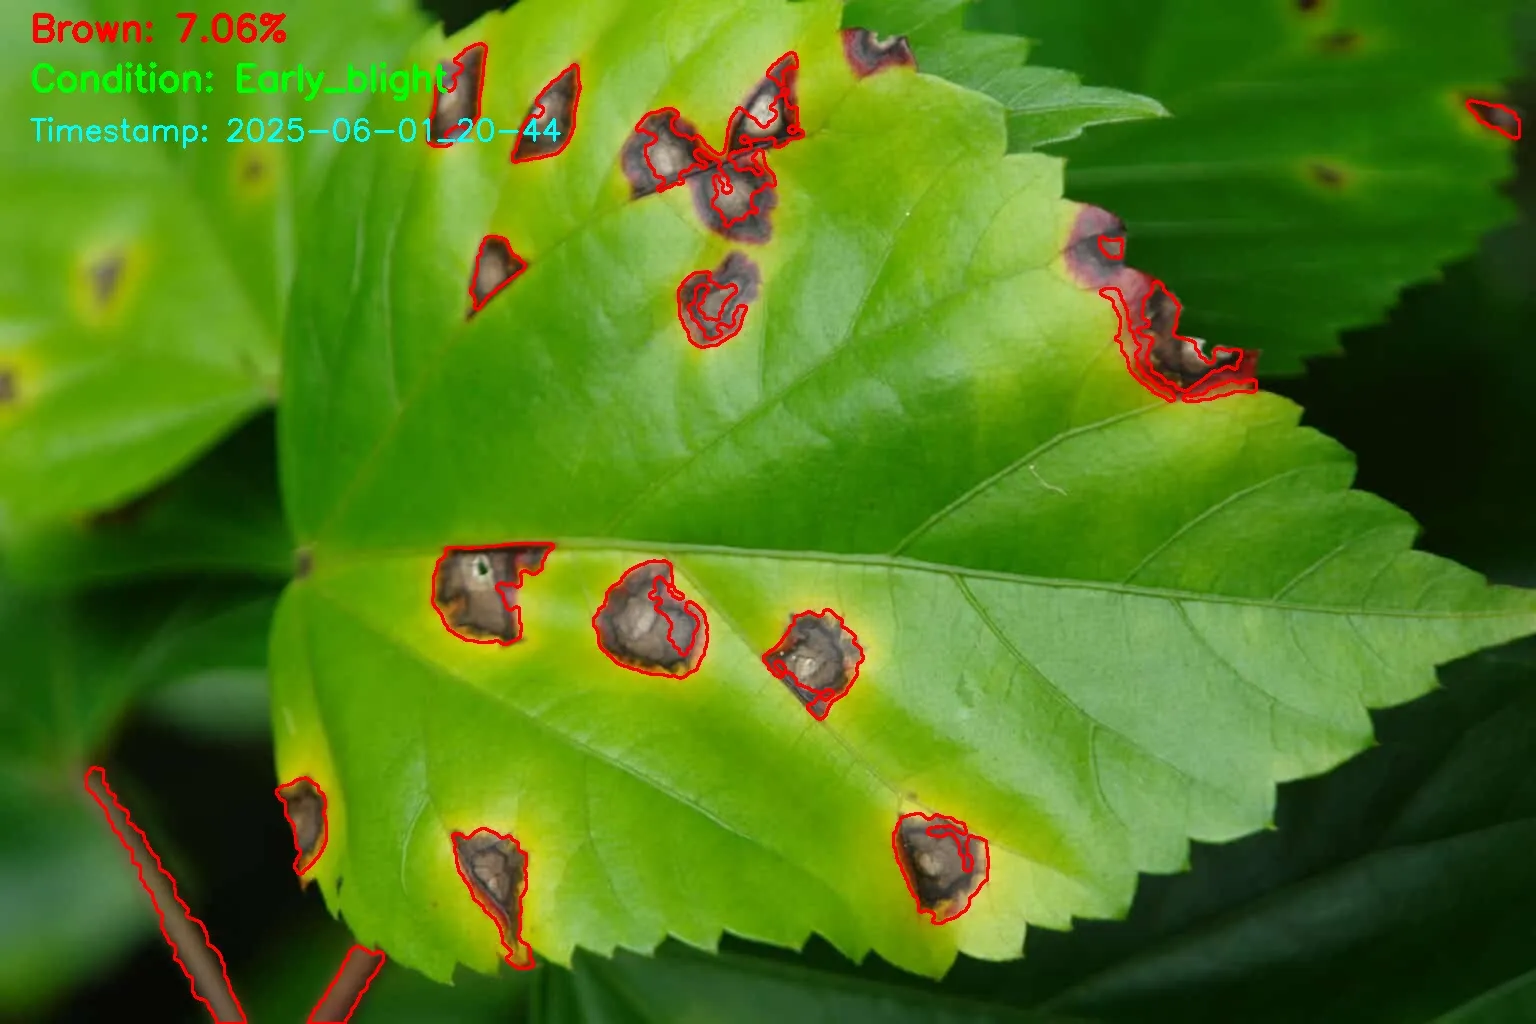
Smart plant incubation system combining environmental sensors, an ESP32 and Raspberry Pi 4B for real-time monitoring and automated irrigation, with a CNN detecting tomato leaf disease at an early stage.
BINUS ASO School of Engineering
BINUS ASO School of Engineering (AeroBASE)
BINUS ASO School of Engineering (AeroBASE)
BINUS ASO School of Engineering
Total Panel Beton
BINUS ASO School of Engineering
BINUS ASO School of Engineering
Mar 2026 - May 2026
Toyohashi University of Technology (豊橋技術科学大学) · Toyohashi, Aichi, Japan
Research and lab assistance on autonomous mobile robot navigation and precision visual alignment. Achieved sub-centimeter docking precision (0.4 mm error at 15 cm staging range) through custom intrinsic camera calibration and a proportional control algorithm, and engineered a reactive state machine for perimeter exploration using windowed LiDAR data.
Sep 2025 - Jan 2026
BINUS ASO School of Engineering · South Tangerang, Indonesia
Supported the Decision Making Under Uncertainty course, guiding 20+ students through Analytical Hierarchy Process models in SuperDecisions. Prepared 10+ lab materials and case studies and delivered 14+ weekly tutorials on hierarchical modelling and pairwise comparison.
Sep 2025 - Jan 2026
BASE C.O.R.E · South Tangerang, Indonesia
Mentored underclassmen through BASE C.O.R.E projects and research, sharing documentation and lessons from previous cohorts to smooth transitions for new members.
Jun 2025 - Sep 2025
Total Panel Beton · Jakarta, Indonesia
Worked with a 3-member R&D team to design, prototype, and test 2 process improvement initiatives, improving production accuracy and consistency by up to 12%. Analyzed 50+ operational and product data points to validate the solutions.
Jul 2024 - Sep 2025
BASE C.O.R.E · South Tangerang, Indonesia
Managed documentation for 20+ lessons and meetings, and organized the division's curriculum and academic calendar for 30+ members.
Feb 2024 - Jul 2024
BASE A.I · South Tangerang, Indonesia
Oversaw the AI Division's transition into BASE Core, preparing handover documents, lesson materials, and project records to keep operations continuous through the leadership change.
Sep 2023 - Oct 2025
AeroBase · South Tangerang, Indonesia
Developed and integrated drone simulation environments in Gazebo using ROS, built and tested object detection models for UAV perception, and designed and debugged ROS packages for navigation, sensor handling, and communication.
Sep 2023 - Oct 2025
ESPORTS Club (EO) · South Tangerang, Indonesia
Organized esports tournaments with 80+ competing teams across Mobile Legends and Valorant, coordinating scheduling, logistics, and live streaming for multi-day events reaching hundreds of participants.
Sep 2023 - Jan 2024
BASE A.I · South Tangerang, Indonesia
Built and tested 3+ machine learning models in Python, processed and analyzed 5+ datasets for training and evaluation, and collaborated with 15+ peers on documentation and project development.
I work at the seam between hardware and software: ROS navigation stacks, vision models quantized for a Raspberry Pi, CAD for the parts that hold them together. Most of my projects start as a physical problem, like picking a strawberry or docking a robot, and end as a system that has been calibrated, tested, and made to work in the real world.
Alongside engineering I have led student organisations, taught lab courses, and run esports tournaments for eighty-plus teams. I speak Indonesian, English, and enough Japanese and Mandarin to get by.
Model · image classification · updated 30 Nov 2025
Dataset · updated 10 Sept 2026
Dataset · updated 9 Sept 2026
Dataset · updated 19 Aug 2026
Model · object detection · updated 22 Dec 2025
Space · gradio · updated 18 Nov 2025
Model · text classification · updated 24 Nov 2025
Model · updated 17 Nov 2025
Dataset · updated 14 Aug 2026
Dataset · updated 9 Sept 2026
Dataset · updated 10 Sept 2026
Read from the Hugging Face and Kaggle APIs at build time on .
What AeroBASE's first competition drone taught us, and how the second one's stack, simulation and detector changed because of it.
How PLANTESA's leaf-disease classifier went from chance to 89.5%, and what a Raspberry Pi and an ESP32 forced out of the design.
What the fish feeder taught me about blocking code, sensors that lie, and testing one part at a time.
Contact
Internships, research positions, and collaborations. Reply within a day or two.
gareth.harrison@binus.ac.id