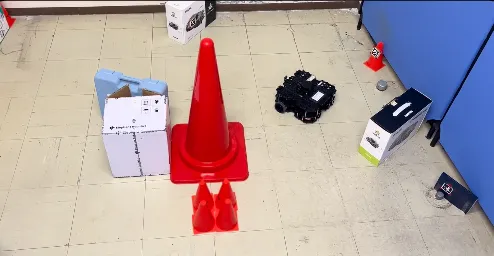
TurtleBot Autonomous Navigation
Autonomous navigation and mapping for a TurtleBot in cluttered indoor environments, combining global path planning with visual servoing and an AprilTag landmark infrastructure to defeat odometry drift.
What I did
- Architected a reactive state machine for autonomous perimeter exploration, using windowed LiDAR data for dynamic obstacle evasion and trap recovery.
- Engineered a custom visual-servoing controller for final docking, reaching 0.4 mm error at a 15 cm staging range and bypassing the limits of the standard ROS navigation stack.
- Ran intrinsic camera calibration for a Raspberry Pi Camera V2 and designed a tiered landmark system to mitigate long-term dead-reckoning drift.